AutelicaTerrain lab
Terrain lab.
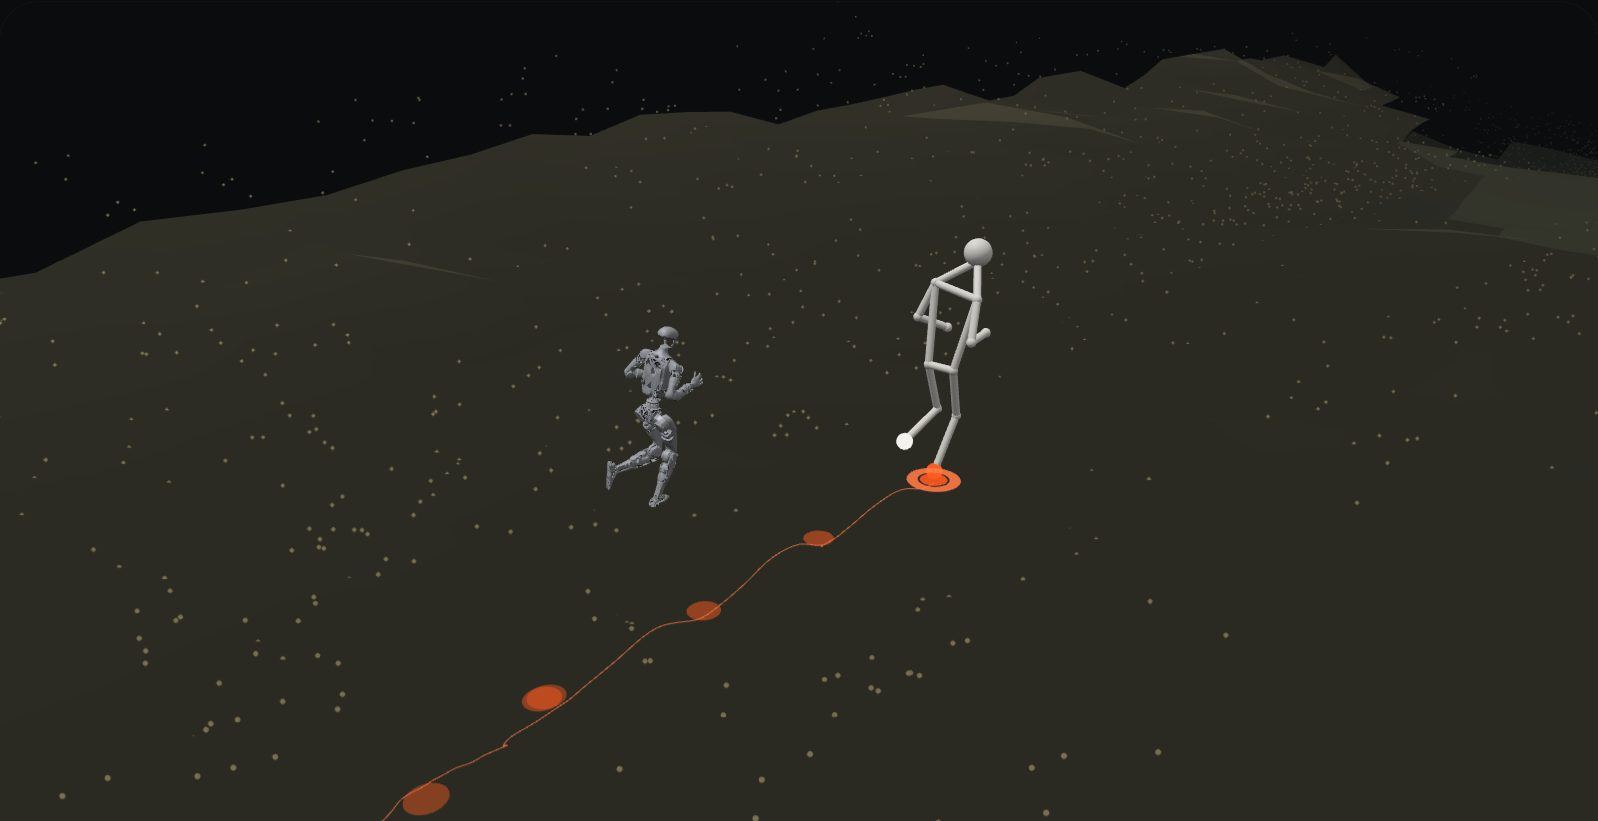
A real site, played on one clock. One person walks and jogs across a park, filmed by three small drones. You see their 3D body on the measured ground, each footfall where it landed, and a Unitree G1 running the same motion in simulation beside them. This is the raw material of a site sim.
Loading the capture…
Capture 02, Oct 10, 2026: three small drones followed one person through a park. The dots are the ground measured from the drone footage, coloured by height; the skeleton is the measured 3D body; orange prints mark where a foot was planted, found from the 3D ankles. The G1 is a Unitree G1 tracking the same motion in physics simulation, drawn 1.3 m to the side. Drag to swing the camera. The capture write-up
From your site to a trained policy
Three stages. Realistic environments of real deployment sites, not stock scenes.
- 01
Capture
The site at very high fidelity: terrain, objects, and people’s whole-body and hand motion on that ground. Fixed cameras or small drones.
- Rig
- Small drones or fixed cameras
- Check
- Error report per clip
- 02
Build the sim
A simulation environment of that exact site: the measured terrain, objects and human motion, in your simulator.
- Scene
- Terrain mesh, height field, MJCF, URDF
- Loads in
- MuJoCo, Isaac Lab
- 03
Train and test
Your policy trained and tested on the site before the robot arrives, with the improvement measured against criteria agreed up front.
- Robots
- Unitree G1, H1-2, robot hands
- Result
- Improvement vs agreed criteria
What goes into each sim, the formats and the checks: how we work.
Headline results · from a different capture
Why measured ground matters. Measured on our Oct 17 terrain capture, not on the clip above.
| Result | What was compared | Write-up |
|---|---|---|
| 10 cm vs ~70 cm | Terrain slopes against survey lidar at p90: measured from drone footage vs guessed from the person’s motion | The Oct 17 capture |
| −0.1 cm | Median distance of the G1’s soles from the measured surface at stance | Accuracy table |
| 12 vs 31 of 210 | Humanoid clips that fall in simulation when trained on a site’s real ground vs flat ground | Terrain and robot training |
Simulation and public benchmarks. Real-robot tests are next, through customer pilots.
Want this for your site?
Tell us where your robot is going and what people do there. We reply with a deployment pilot plan: what we capture, the sim we build and the criteria we report against.